How to Choose a Pepperl Fuchs Inductive Sensor?
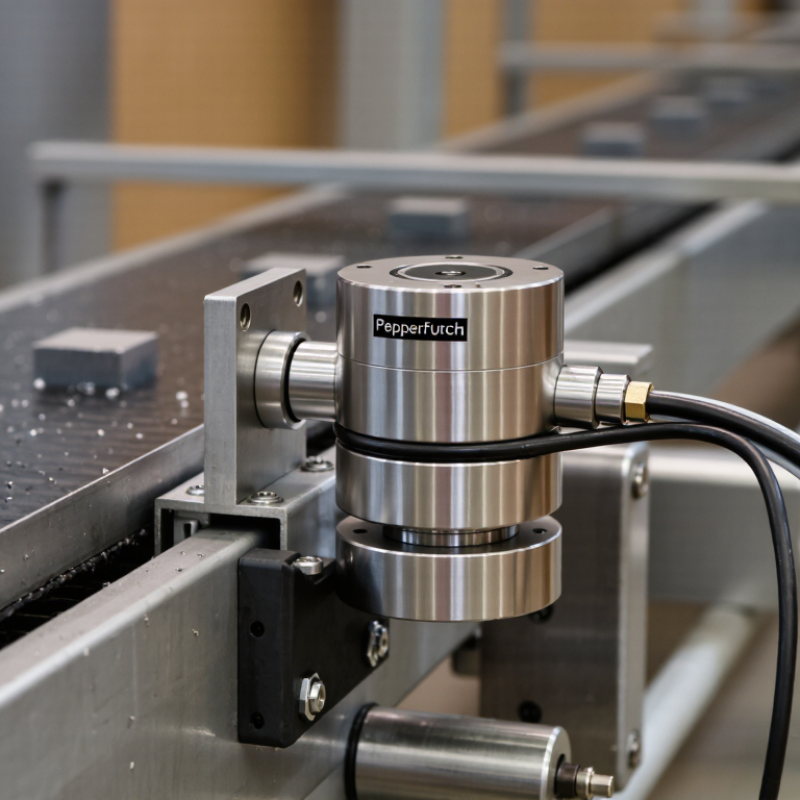
Choosing the right pepperl-fuchs Inductive sensor begins with the application, not the product catalogue. Metal target size, sensing distance, mounting space, speed, temperature, and electrical connection all affect performance. A sensor beside a conveyor may face oil mist, vibration, metal chips, and repeated impacts. A laboratory fixture may need only stable detection and a compact body.
Dr. Gunther Kegel, a recognized Pepperl+Fuchs industry expert, has often expressed a practical principle: “Technology must serve the application, not the other way around.” That idea matters here. A flush sensor may suit a tight mounting position, while a non-flush model can provide greater sensing range. Stainless steel housings may help in harsh environments, but they do not replace correct installation. Small details matter.
Measure the target carefully. Check the required switching frequency. Confirm the output type, voltage, connector, and protection rating. Then compare the datasheet with the real machine, not an idealized drawing. This step is easy to underestimate.
Field experience also reveals uncomfortable truths. A sensor can be technically correct yet poorly positioned. Excessive clearance, nearby metal brackets, or cable stress may cause unstable signals. No selection guide can remove every risk. Testing remains valuable.
This guide explains how to choose a pepperl-fuchs Inductive sensor with a disciplined, application-focused method. It considers detection reliability, environmental demands, installation limits, and long-term maintenance. The goal is not the most expensive sensor. It is the most dependable fit.
Define the Sensing Application and Detection Requirements
Choosing an inductive sensor starts with the application, not the catalog. Define the target clearly. Inductive sensors detect metal, but alloys affect sensing distance. Steel usually allows a longer range than aluminum or copper. Measure the actual target, not an ideal sample. Record its size, shape, surface condition, and movement. Keep it simple. Note the smallest detection gap and the fastest operating cycle. A rotating bolt may require a different response speed than a slowly moving steel plate.
Inspect the installation environment before selecting the housing. Oil, coolant, dust, vibration, and frequent cleaning can change sensor performance. Check the available mounting space and nearby metal structures. Flush mounting can reduce interference in tight locations. Non-flush mounting may provide greater sensing distance, but it needs more clearance. During field checks, I have seen suitable sensors fail because a bracket altered the sensing field. That detail is easy to miss. Test the sensor in its final position whenever possible.
Confirm the supply voltage, output type, switching frequency, connector, and cable length. The controller must match the sensor’s electrical output, such as PNP or NPN. Normally open and normally closed behavior also affects machine response after power loss. Allow for hysteresis and mechanical tolerance near the switching point. Test the smallest target at the widest expected gap, including temperature changes and vibration. Nominal specifications are useful, but real conditions are less forgiving. A short trial may reveal a mounting problem before production begins.
Select the Appropriate Pepperl+Fuchs Sensor Type
Choosing an inductive sensor starts with the sensing task, not the catalog number. Define the target material, detection distance, speed, and mounting space. Ferrous targets usually provide the longest range. Aluminum and brass often reduce it. Select a shielded, flush-mount type when metal surrounds the sensing face. Choose an unshielded type when greater range matters and side clearance is available. The wrong body style can create false triggers.
Output selection is equally important. PNP and NPN outputs must match the controller’s input circuit. AC or DC compatibility should never be assumed. For fast counting, check switching frequency and response time. For dirty washdown areas, verify the enclosure rating, connector seal, and temperature range. An IP rating helps, but cable routing still matters. One overlooked detail.
The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023. This volume increases the need for stable position and presence detection. Grand View Research has projected approximately 9% annual growth for the industrial sensors market through 2030. These figures support careful specification, not automatic overengineering. I have seen teams choose the longest sensing range available, then fight vibration and cross-talk during commissioning. A shorter-range sensor may perform better. Test the sensor with the real target, bracket, speed, and surrounding metal. Allow for production tolerances. My own selection checklist would still include one imperfect step: a live trial after installation, because laboratory distances rarely represent a moving production line.
How to Choose an Inductive Sensor
Select the sensor type by checking the target material, required sensing distance, installation space, and output interface. The chart shows typical sensing-distance correction factors relative to a ferrous-steel target.
A ferrous-steel target is used as the reference value of 1.00. Stainless steel, brass, aluminum, and copper generally produce shorter sensing distances because their electrical and magnetic properties differ. Actual performance depends on sensor construction, target size, thickness, shape, and mounting conditions.
Verify Installation Compatibility and Long-Term Reliability
How to Choose a Pepperl Fuchs Inductive Sensor?
Verify installation compatibility before comparing sensing ranges or prices. The International Federation of Robotics reported 541,302 industrial robot installations in 2023. More automated equipment means more sensors facing vibration, oil mist, heat, and repeated impacts. A suitable inductive sensor must match the target metal, detection distance, mounting method, and switching frequency.
Measure the real gap, not the catalog maximum. Leave practical margin when targets wobble on a conveyor. Check whether flush mounting changes the sensing distance. A stainless-steel bracket may also distort the result. Small details matter. Confirm connector orientation, cable bend radius, and available clearance around the sensing face. Then compare the sensor’s voltage, current, response time, and output type with the controller.
Long-term reliability begins with environmental verification. IP67 protection supports temporary immersion under defined test conditions, according to IEC 60529; it does not guarantee resistance to every chemical or washdown routine. Check the manufacturer’s temperature range, shock and vibration ratings, and material compatibility. The ISO 13849-1 framework also reminds engineers to consider diagnostic behavior within safety-related control systems, where applicable. Do not treat a higher IP rating as a complete reliability plan. I have seen installations fail because condensation entered through a damaged cable, not the sensor body. A short trial beside the actual machine can expose false switching, mounting resonance, or unexpected metal interference before full deployment.